
Nowadays the automatic conveyor systems and robots increasingly substitute human labor overtaking various manufacturing processes such as palletizing, packing and transporting goods within manufacturing department [1] [2]. The reason is that automatic conveyors and robots have many advantages over human labor, for example: i) much higher performance speed; ii) better quality and higher positioning accuracy; iii) possibility to work without any break; iv) lower operating costs; v) possibility to avoid errors produced by people because of their emotional state and fatigue.
We have created a mini version of a pneumatic assembly line Fig. 1. and connected it to the existing robot. We are planning that the new equipment will be controlled via robot control unit. In such a way we will be able to simulate different work processes conducted by both the robot and the conveyor. Also, we will be able to find the best solution for each task associated with goods transportation.
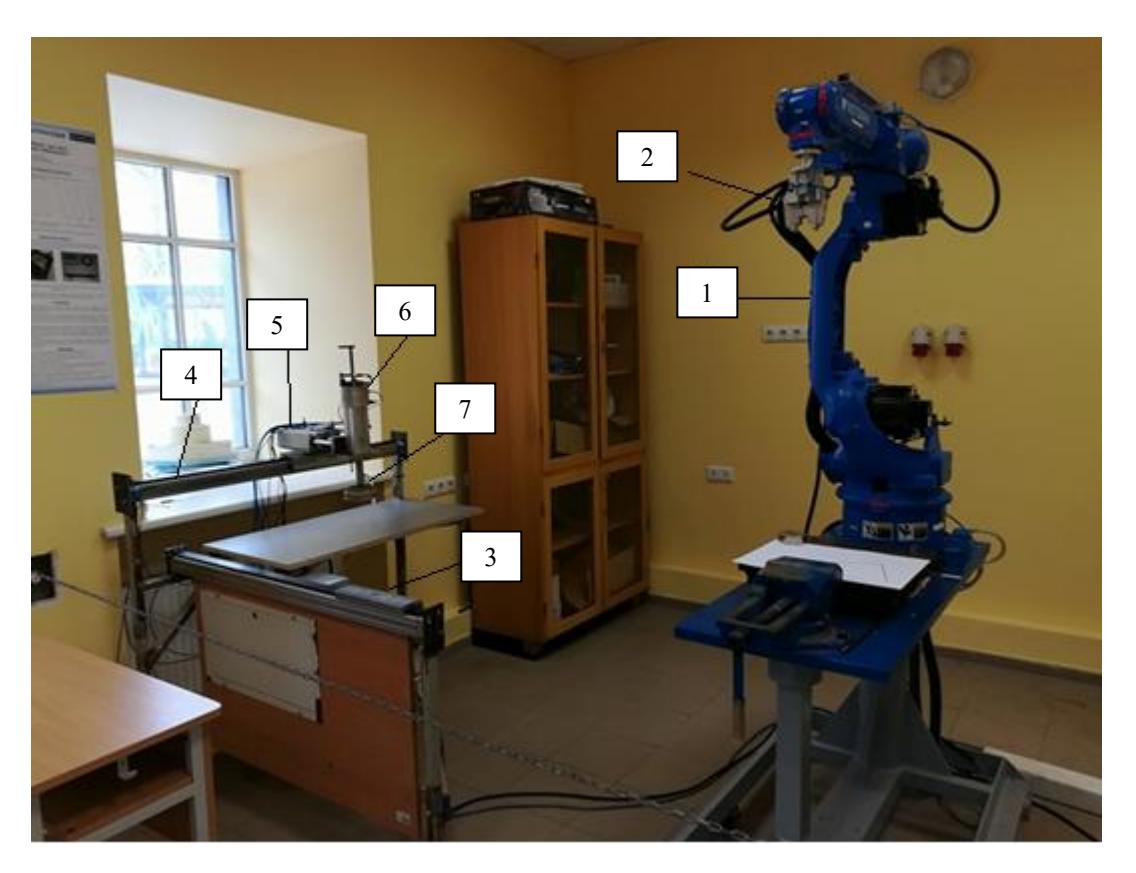
Despite the fact that our model is already constructed, there is possibility to attach several more sensors, for example: on the table can be installed capacitive sensor, ultrasonic or other sensor to detect if there any object or not. So, if there are some ideas how to modernize this project, they will be taken into to make our model more efficient and interesting in teaching process.