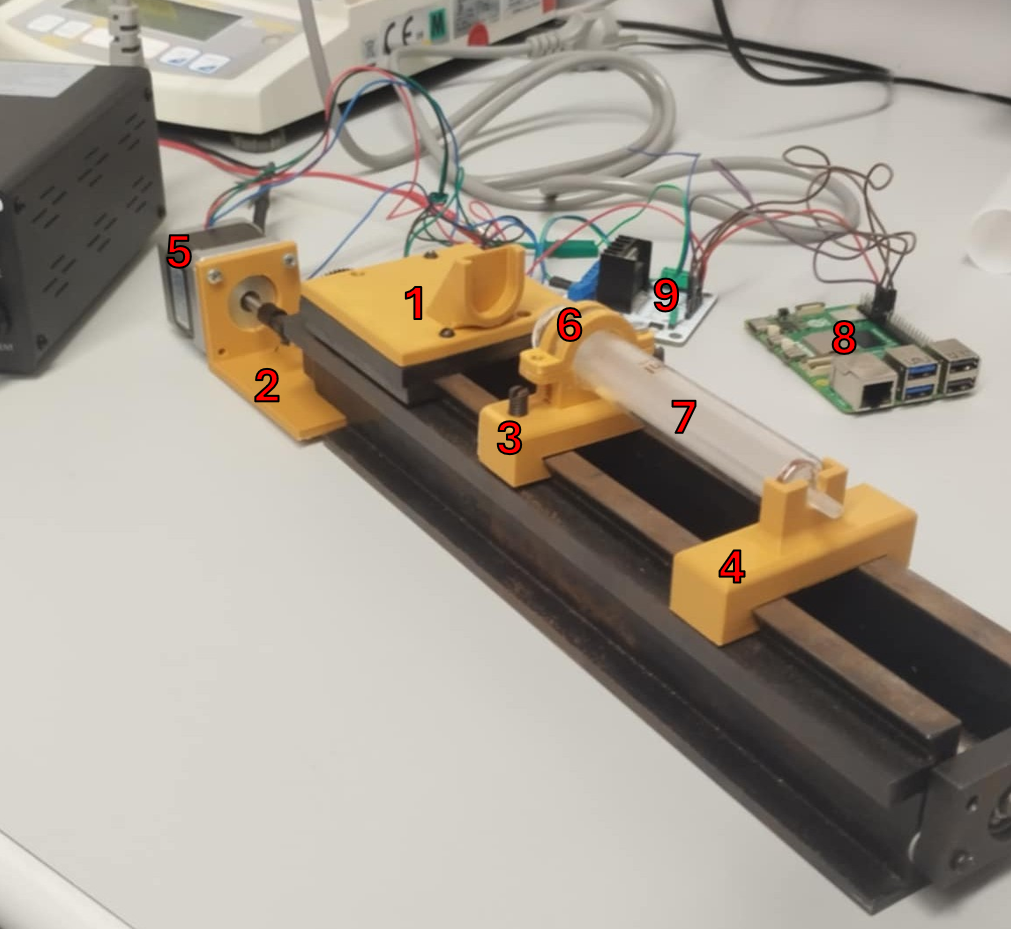
Microfluidic experiments require stable and accurate dosing of small volumes of fluid, which is why practical, easily modifiable, and inexpensive syringe pumps are an important part of laboratory equipment.
This work addresses the task of creating a prototype syringe pump for microfluidics, capable of repeatedly dispensing volumes of 0.1 – 10 ml and automatically converting the user-specified volume into stepper motor control steps.
The proposed solution is a self-designed mechanical structure manufactured using fused deposition modeling (FDM) 3D printing, using polylactic acid (PLA) plastic, acrylonitrile butadiene styrene copolymer (ABS) for the load-bearing joint, integrated with a NEMA17 stepper motor, a 0.56 mm step screw mechanism, Raspberry Pi 5 control (Python, GPIO), and an L298N driver. A 10 ml glass syringe filled with water was used for testing.
Experimental calibration showed that the optimal setting for a nominal 1 mL volume is 2370 steps/mL, and that dosing accuracy is primarily limited by mechanical backlash during direction reversal: 81.9 ± 2.6 steps, corresponding to a volume error of 0.034 ± 0.002 mL. It was found that, after calibration, changing the step delay (0.002 – 0.01) had no significant effect on volume accuracy, while adding tubing increased measurement variability and reduced accuracy.
The results confirm that the developed syringe pump is functional and suitable for laboratory microfluidic testing, providing repeatable dosing after calibration. Accuracy is mainly limited by backlash during direction changes, and added tubing increases variability; therefore, reducing mechanical play and increasing stiffness are key. Future work will optimize the drive and coupling, use lower-backlash components, and validate performance with different syringe sizes and real microfluidic channels.